We can't find the internet
Attempting to reconnect
Something went wrong
Hang in there while we get back on track
£54.94
It has never been this cheap. We have no record of a lower price.
£55 today · cheaper than every other day in the last 3 months
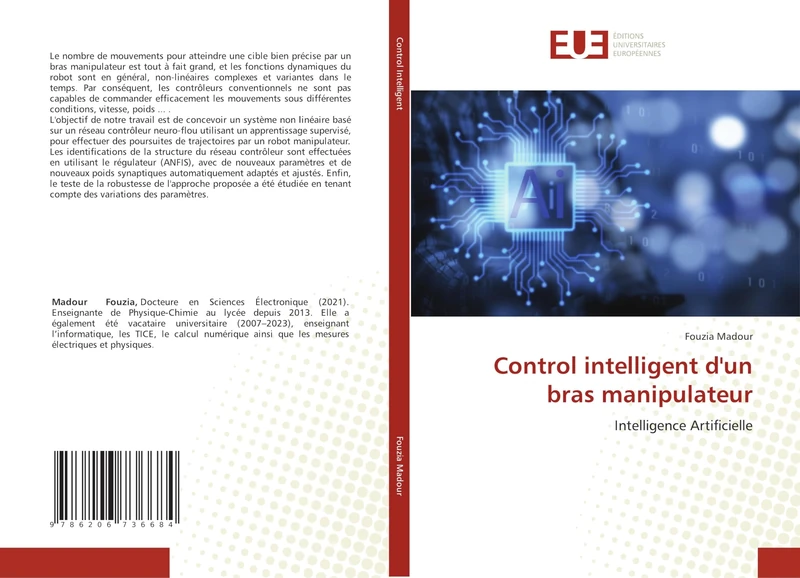
ÉDITIONS UNIVERSITAIRES EUROPÉENNES Control intelligent d'un bras manipulateur: Intelligence Artificielle
Price data last checked 37 day(s) ago - refreshing...
We'll watch every seller, every day. One email when your price arrives.
Price History & Forecast
Grey patches = out of stock. Cheaper = lower on the chart. Hover for exact prices.
Last 54 days · 54 data points (no recent data)
Price data last checked 37 day(s) ago - refreshing...
NEW HERE?
Amazon shows you one price. We show you all of them.
Tosheroon watches Amazon prices so you don't have to. Every product on Amazon has a price history — we make it visible. Set the price you'd actually pay, and we'll email you the second it gets there. No app, no account, one email.
WHAT'S ON THIS PAGE
when this has been cheap or pricey
where the price is heading next
all-time high & low, recent range
name your number, we'll email you
Price Distribution
Price distribution over 54 days • 2 price levels
Price Analysis
Most common price: £59 (36 days, 66.7%)
Price range: £55 - £59
Price levels: 2 different prices over 54 days
Description
Product Specifications
- Format
- paperback
- ASIN
- 6206736687
- Domain
- Amazon UK
- Release Date
- 15 April 2025
- Listed Since
- 06 May 2025
Barcode
No barcode data available
Similar Products You Might Like
Commande Robuste des Systèmes: Théories et Applications à la Commande de Robots manipulateurs à Muscles Artificiels
ÉDITIONS UNIVERSITAIRES EUROPÉENNES
Commande neuronale robuste d'un robot manipulateur: Commande neuronale robuste d'un robot manipulateur dans un sens paramétral et environnemental (Omn.Pres.Franc.)
OmniScriptum
Mains Mécaniques Articulées pour la Saisie d'Objets: Modélisation et Commande
ÉDITIONS UNIVERSITAIRES EUROPÉENNES
Stratégie de prise pour la manipulation d'objets déformables
ÉDITIONS UNIVERSITAIRES EUROPÉENNES
Task-Space Sensory Feedback Control of Robot Manipulators: 73 (Intelligent Systems, Control and Automation: Science and Engineering, 73)
Springer
CONCEPTION DE CONTRÔLEURS DYNAMIQUES POUR LES SYSTÈMES NON LINÉAIRES
Multi-Arm Cooperating Robots: Dynamics and Control: 30 (Intelligent Systems, Control and Automation: Science and Engineering, 30)
Springer
Analyse der Konformitätskontrolle eines zweiachsigen Robotergreifers: Charakterisierung und Analyse verschiedener Parameter für die Konstruktion eines prothetischen Roboterarms
Reinforcement Learning of Bimanual Robot Skills: 134 (Springer Tracts in Advanced Robotics, 134)
Springer
Nonlinear Control of Vehicles and Robots (Advances in Industrial Control)
Springer
Interaction Control of Robot Manipulators: Six degrees-of-freedom tasks: 3 (Springer Tracts in Advanced Robotics, 3)
Springer
The “Hand-eye-brain” System of Intelligent Robot: From Interdisciplinary Perspective of Information Science and Neuroscience (Research on Intelligent Manufacturing)
Springer
Interaction Control of Robot Manipulators: Six degrees-of-freedom tasks: 3 (Springer Tracts in Advanced Robotics, 3)
Springer
Inductive Biases in Machine Learning for Robotics and Control: 156 (Springer Tracts in Advanced Robotics, 156)
Springer
Inductive Biases in Machine Learning for Robotics and Control: 156 (Springer Tracts in Advanced Robotics, 156)
Springer
Neuro-Fuzzy Control of Industrial Systems with Actuator Nonlinearities (Frontiers in Applied Mathematics): 24 (Frontiers in Applied Mathematics, Series Number 24)
Society for Industrial and Applied Mathematics (SIAM)
Fundamentals in Modeling and Control of Mobile Manipulators (Automation and Control Engineering)
CRC Press
Transferring Human Impedance Regulation Skills to Robots: 110 (Springer Tracts in Advanced Robotics, 110)
Springer
Intelligent Autonomous Systems: Foundations and Applications: 275 (Studies in Computational Intelligence, 275)
Springer
Control System Design for Electrical Stimulation in Upper Limb Rehabilitation: Modelling, Identification and Robust Performance
Springer
Whole-Body Impedance Control of Wheeled Humanoid Robots: 116 (Springer Tracts in Advanced Robotics, 116)
Springer
Robot Physical Interaction through the combination of Vision, Tactile and Force Feedback: Applications to Assistive Robotics: 84 (Springer Tracts in Advanced Robotics, 84)
Springer
Robot Force Control: 540 (The Springer International Series in Engineering and Computer Science, 540)
Springer
Robot Force Control: 540 (The Springer International Series in Engineering and Computer Science, 540)
Springer