We can't find the internet
Attempting to reconnect
Something went wrong
Hang in there while we get back on track
£60.00
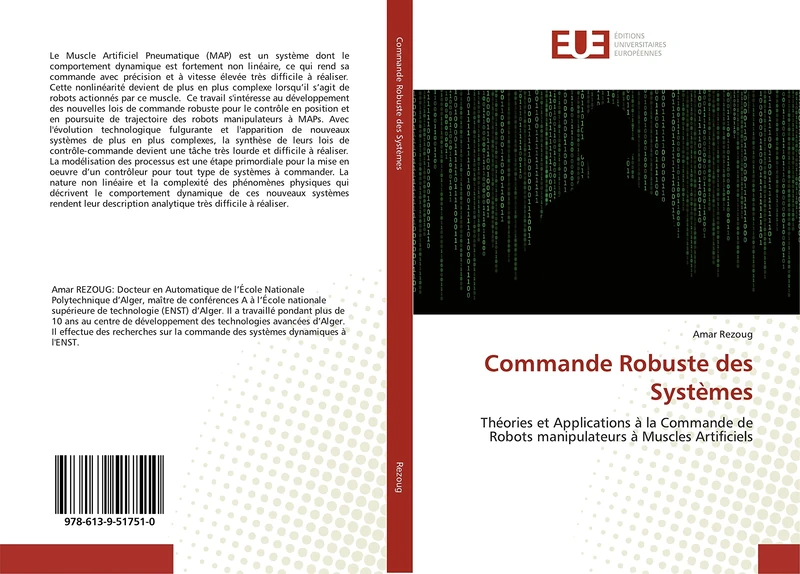
ÉDITIONS UNIVERSITAIRES EUROPÉENNES Commande Robuste des Systèmes: Théories et Applications à la Commande de Robots manipulateurs à Muscles Artificiels
Price data last checked 21 day(s) ago - will refresh soon
We'll watch every seller, every day. One email when your price arrives.
It has never been this cheap. We have no record of a lower price.
£60 today · cheaper than every other day in the last 3 months
NEW HERE?
Amazon shows you one price. We show you all of them.
Tosheroon watches Amazon prices so you don't have to. Every product on Amazon has a price history — we make it visible. Set the price you'd actually pay, and we'll email you the second it gets there. No app, no account, one email.
WHAT'S ON THIS PAGE
when this has been cheap or pricey
where the price is heading next
all-time high & low, recent range
name your number, we'll email you
Price History & Forecast
Grey patches = out of stock. Cheaper = lower on the chart. Hover for exact prices.
Last 70 days · 70 data points (no recent data)
Price Distribution
Price distribution over 70 days • 1 price levels
Price Analysis
Most common price: £60 (70 days, 100.0%)
Price range: £60 - £60
Price levels: 1 different prices over 70 days
Description
Product Specifications
- Format
- paperback
- ASIN
- 6139517516
- Domain
- Amazon UK
- Release Date
- 20 January 2020
- Listed Since
- 16 February 2020
Barcode
No barcode data available
Similar Products You Might Like
Multi-Arm Cooperating Robots: Dynamics and Control: 30 (Intelligent Systems, Control and Automation: Science and Engineering, 30)
Springer
Nonlinear Control of Vehicles and Robots (Advances in Industrial Control)
Springer
Vehicle-Manipulator Systems: Modeling for Simulation, Analysis, and Control (Advances in Industrial Control)
Springer
Fundamentals in Modeling and Control of Mobile Manipulators (Automation and Control Engineering)
CRC Press
Vehicle-Manipulator Systems: Modeling for Simulation, Analysis, and Control (Advances in Industrial Control)
Springer
Interaction Control of Robot Manipulators: Six degrees-of-freedom tasks: 3 (Springer Tracts in Advanced Robotics, 3)
Springer
Interaction Control of Robot Manipulators: Six degrees-of-freedom tasks: 3 (Springer Tracts in Advanced Robotics, 3)
Springer
Dynamics of Underactuated Multibody Systems: Modeling, Control and Optimal Design: 205 (Solid Mechanics and Its Applications, 205)
Springer
Electroactive Polymers for Robotic Applications: Artificial Muscles and Sensors
Springer
Robust Control of Robots: Fault Tolerant Approaches
Springer
Modeling and IPC Control of Interactive Mechanical Systems - A Coordinate-Free Approach: 266 (Lecture Notes in Control and Information Sciences, 266)
Springer
Robot Force Control: 540 (The Springer International Series in Engineering and Computer Science, 540)
Springer
Robot Force Control: 540 (The Springer International Series in Engineering and Computer Science, 540)
Springer
Electroactive Polymers for Robotic Applications: Artificial Muscles and Sensors
Springer
Mains Mécaniques Articulées pour la Saisie d'Objets: Modélisation et Commande
ÉDITIONS UNIVERSITAIRES EUROPÉENNES
Distributed Parameter Modeling and Boundary Control of Flexible Manipulators
Springer

Commande neuronale robuste d'un robot manipulateur: Commande neuronale robuste d'un robot manipulateur dans un sens paramétral et environnemental (Omn.Pres.Franc.)
OmniScriptum
Logique floue et controle des systemes photovoltaïques: Commande floue type-2 et MPPT floue pour le pompage photovoltaïque
UNIV EUROPEENNE
Task-Space Sensory Feedback Control of Robot Manipulators: 73 (Intelligent Systems, Control and Automation: Science and Engineering, 73)
Springer
Biomimetic Robotic Artificial Muscles
World Scientific Publishing Company
Advanced Control of Wheeled Inverted Pendulum Systems
Springer

Commande robuste des systèmes à commutation: Sur la stabilité et la stabilisation robuste des systèmes à commutation (Omn.Univ.Europ.)
OmniScriptum
Control of Complex Systems
Springer
Model-Based Tracking Control of Nonlinear Systems (CRC Series--Modern Mechanics and Mathematics)
CRC Press