We can't find the internet
Attempting to reconnect
Something went wrong
Hang in there while we get back on track
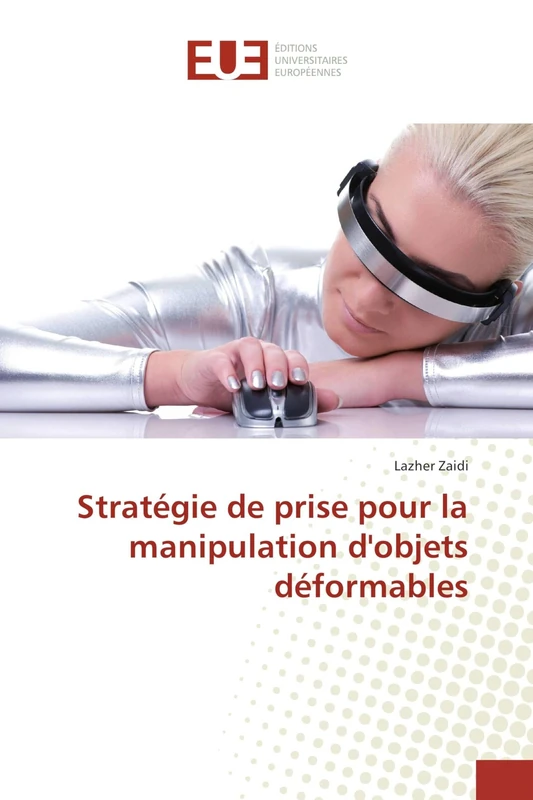
£54.00
ÉDITIONS UNIVERSITAIRES EUROPÉENNES Stratégie de prise pour la manipulation d'objets déformables
Price data last checked 22 day(s) ago - will refresh soon
We'll watch every seller, every day. One email when your price arrives.
It has never been this cheap. We have no record of a lower price.
£54 today · cheaper than every other day in the last 3 months
NEW HERE?
Amazon shows you one price. We show you all of them.
Tosheroon watches Amazon prices so you don't have to. Every product on Amazon has a price history — we make it visible. Set the price you'd actually pay, and we'll email you the second it gets there. No app, no account, one email.
WHAT'S ON THIS PAGE
when this has been cheap or pricey
where the price is heading next
all-time high & low, recent range
name your number, we'll email you
Price History & Forecast
Grey patches = out of stock. Cheaper = lower on the chart. Hover for exact prices.
Last 69 days · 69 data points (no recent data)
Price Distribution
Price distribution over 69 days • 1 price levels
Price Analysis
Most common price: £54 (69 days, 100.0%)
Price range: £54 - £54
Price levels: 1 different prices over 69 days
Description
Product Specifications
- Format
- paperback
- ASIN
- 3841616062
- Domain
- Amazon UK
- Release Date
- 23 November 2016
- Listed Since
- 16 December 2016
Barcode
No barcode data available
Similar Products You Might Like
Mains Mécaniques Articulées pour la Saisie d'Objets: Modélisation et Commande
ÉDITIONS UNIVERSITAIRES EUROPÉENNES
Dextrous Robot Hands
Springer
Underactuated Robotic Hands: 40 (Springer Tracts in Advanced Robotics, 40)
Springer
Grasping in Robotics: 10 (Mechanisms and Machine Science, 10)
Springer
From Robot to Human Grasping Simulation: 19 (Cognitive Systems Monographs, 19)
Springer

Advanced Bimanual Manipulation: Results from the DEXMART Project: 80 (Springer Tracts in Advanced Robotics, 80)
Springer
Approaching Human Performance: The Functionality-Driven Awiwi Robot Hand: 98 (Springer Tracts in Advanced Robotics, 98)
Springer
Interaction Control of Robot Manipulators: Six degrees-of-freedom tasks: 3 (Springer Tracts in Advanced Robotics, 3)
Springer
Interaction Control of Robot Manipulators: Six degrees-of-freedom tasks: 3 (Springer Tracts in Advanced Robotics, 3)
Springer

Mechanics and Control of Soft-fingered Manipulation
Springer
Multi-Arm Cooperating Robots: Dynamics and Control: 30 (Intelligent Systems, Control and Automation: Science and Engineering, 30)
Springer
Reinforcement Learning of Bimanual Robot Skills: 134 (Springer Tracts in Advanced Robotics, 134)
Springer
The Human Hand as an Inspiration for Robot Hand Development: 95 (Springer Tracts in Advanced Robotics, 95)
Springer
Robot Dynamic Manipulation: Perception of Deformable Objects and Nonprehensile Manipulation Control: 144 (Springer Tracts in Advanced Robotics, 144)
Springer
Vehicle-Manipulator Systems: Modeling for Simulation, Analysis, and Control (Advances in Industrial Control)
Springer
Commande Robuste des Systèmes: Théories et Applications à la Commande de Robots manipulateurs à Muscles Artificiels
ÉDITIONS UNIVERSITAIRES EUROPÉENNES
Vehicle-Manipulator Systems: Modeling for Simulation, Analysis, and Control (Advances in Industrial Control)
Springer
Robot Force Control: 540 (The Springer International Series in Engineering and Computer Science, 540)
Springer
Robot Force Control: 540 (The Springer International Series in Engineering and Computer Science, 540)
Springer
Fundamentals in Modeling and Control of Mobile Manipulators (Automation and Control Engineering)
CRC Press
Multi-point Interaction with Real and Virtual Objects: 18 (Springer Tracts in Advanced Robotics, 18)
Springer
Robot Physical Interaction through the combination of Vision, Tactile and Force Feedback: Applications to Assistive Robotics: 84 (Springer Tracts in Advanced Robotics, 84)
Springer
Control Theory of Multi-fingered Hands: A Modelling and Analytical–Mechanics Approach for Dexterity and Intelligence
Springer
Kinematic Analysis of Robot Manipulators
Cambridge University Press