£84.99

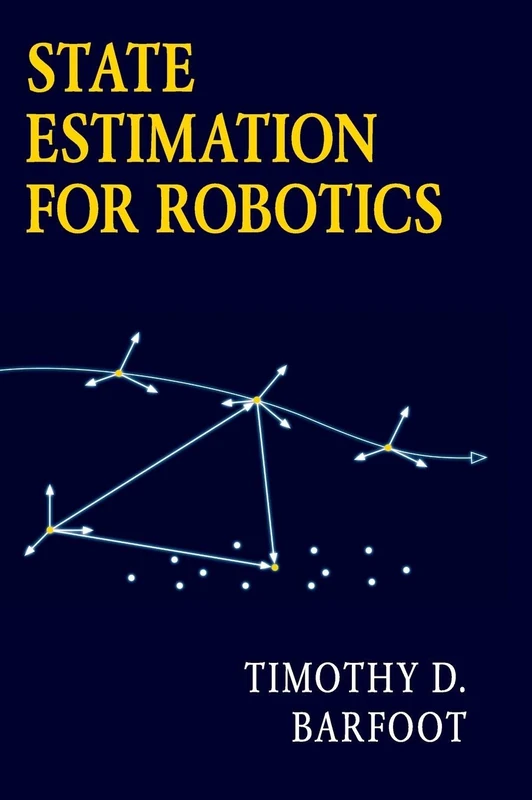
Cambridge University Press State Estimation for Robotics

Price data last checked 23 day(s) ago - will refresh soon

View at Amazon

We'll watch every seller, every day. One email when your price arrives.

It has never been this cheap. We have no record of a lower price.

£85 today · cheaper than every other day in the last 3 months

NEW HERE?

Amazon shows you one price. We show you all of them.

Tosheroon watches Amazon prices so you don't have to. Every product on Amazon has a price history — we make it visible. Set the price you'd actually pay, and we'll email you the second it gets there. No app, no account, one email.

WHAT'S ON THIS PAGE

↓ Price chart
when this has been cheap or pricey
↓ Forecast
where the price is heading next
↓ Statistics
all-time high & low, recent range
↑ Price alert
name your number, we'll email you

Price History & Forecast

Grey patches = out of stock. Cheaper = lower on the chart. Hover for exact prices.

Last 68 days · 68 data points (no recent data)

Historical
Generating forecast…
£171.10 £76.38 £97.05 £117.71 £138.38 £159.04 £179.71 09 July 2026 25 July 2026 11 August 2026 28 August 2026 14 September 2026

Price Distribution

Price distribution over 68 days • 3 price levels

Days at Price
Current Price
16 days · current 37 days 15 days 0 9 19 28 37 £85 £168 £171 Days at Price

Price Analysis

Most common price: £168 (37 days, 54.4%)

Price range: £85 - £171

Price levels: 3 different prices over 68 days

Description

A key aspect of robotics today is estimating the state, such as position and orientation, of a robot as it moves through the world. Most robots and autonomous vehicles depend on noisy data from sensors such as cameras or laser rangefinders to navigate in a three-dimensional world. This book presents common sensor models and practical advice on how to carry out state estimation for rotations and other state variables. It covers both classical state estimation methods such as the Kalman filter, as well as important modern topics such as batch estimation, the Bayes filter, sigmapoint and particle filters, robust estimation for outlier rejection, and continuous-time trajectory estimation and its connection to Gaussian-process regression. The methods are demonstrated in the context of important applications such as point-cloud alignment, pose-graph relaxation, bundle adjustment, and simultaneous localization and mapping. Students and practitioners of robotics alike will find this a valuable resource.

Product Specifications

Format
hardcover
Domain
Amazon UK
Release Date
31 August 2017
Listed Since
25 March 2017

Barcode

No barcode data available

Similar Products You Might Like
SLAM Techniques Application for Mobile Robot in Rough Terrain: 87 (Mechanisms and Machine Science, 87)
83% match

SLAM Techniques Application for Mobile Robot in Rough Terrain: 87 (Mechanisms and Machine Science, 87)

Springer
£108.01 08 Aug 2026
Structure from Motion using the Extended Kalman Filter: 75 (Springer Tracts in Advanced Robotics, 75)
83% match

Structure from Motion using the Extended Kalman Filter: 75 (Springer Tracts in Advanced Robotics, 75)

Springer
£75.70 13 Aug 2026
Structure from Motion using the Extended Kalman Filter: 75 (Springer Tracts in Advanced Robotics, 75)
83% match

Structure from Motion using the Extended Kalman Filter: 75 (Springer Tracts in Advanced Robotics, 75)

Springer

£74.68 08 Aug 2026
Fundamentals of Object Tracking
82% match

Fundamentals of Object Tracking

Cambridge University Press

£83.72 13 Aug 2026
Filtering and System Identification: A Least Squares Approach
82% match

Filtering and System Identification: A Least Squares Approach

Cambridge University Press
£97.00 05 Aug 2026
State Estimation and Control for Low-cost Unmanned Aerial Vehicles
82% match

State Estimation and Control for Low-cost Unmanned Aerial Vehicles

Springer

£75.40 18 Aug 2026
Applied State Estimation and Association (MIT Lincoln Laboratory Series)
81% match

Applied State Estimation and Association (MIT Lincoln Laboratory Series)

MIT Press
£83.08 04 Aug 2026
Environment Learning for Indoor Mobile Robots: A Stochastic State Estimation Approach to Simultaneous Localization and Map Building: 23 (Springer Tracts in Advanced Robotics, 23)
81% match

Environment Learning for Indoor Mobile Robots: A Stochastic State Estimation Approach to Simultaneous Localization and Map Building: 23 (Springer Tracts in Advanced Robotics, 23)

Springer
£74.16 06 Aug 2026
Robotics for Electronics Manufacturing: Principles and Applications in Cleanroom Automation
81% match

Robotics for Electronics Manufacturing: Principles and Applications in Cleanroom Automation

Cambridge University Press
£97.00 29 Aug 2026
Probabilistic Approaches to Robotic Perception: 91 (Springer Tracts in Advanced Robotics, 91)
81% match

Probabilistic Approaches to Robotic Perception: 91 (Springer Tracts in Advanced Robotics, 91)

Springer
£76.18 04 Aug 2026
Site Automation: Automated/Robotic On-Site Factories (Cambridge Handbooks on Construction Robotics)
81% match

Site Automation: Automated/Robotic On-Site Factories (Cambridge Handbooks on Construction Robotics)

Cambridge University Press
£95.76 29 Aug 2026
Biomimetic Robotics: Mechanisms and Control
81% match

Biomimetic Robotics: Mechanisms and Control

Cambridge University Press
£63.81 26 Aug 2026
3D-Position Tracking and Control for All-Terrain Robots: 43 (Springer Tracts in Advanced Robotics, 43)
81% match

3D-Position Tracking and Control for All-Terrain Robots: 43 (Springer Tracts in Advanced Robotics, 43)

Springer

£73.71 08 Aug 2026
Probability, Random Processes, and Statistical Analysis: Applications to Communications, Signal Processing, Queueing Theory and Mathematical Finance
81% match

Probability, Random Processes, and Statistical Analysis: Applications to Communications, Signal Processing, Queueing Theory and Mathematical Finance

Cambridge University Press
£74.00 08 Aug 2026
Kinematic Analysis of Robot Manipulators
81% match

Kinematic Analysis of Robot Manipulators

Cambridge University Press
£105.00 30 Aug 2026
Geometric Fundamentals of Robotics (Monographs in Computer Science)
81% match

Geometric Fundamentals of Robotics (Monographs in Computer Science)

Springer

£54.71 05 Aug 2026
Detection and Estimation for Communication and Radar Systems
81% match

Detection and Estimation for Communication and Radar Systems

Cambridge University Press
£73.99 30 Jul 2026
Task-Space Sensory Feedback Control of Robot Manipulators: 73 (Intelligent Systems, Control and Automation: Science and Engineering, 73)
80% match

Task-Space Sensory Feedback Control of Robot Manipulators: 73 (Intelligent Systems, Control and Automation: Science and Engineering, 73)

Springer
£75.66 05 Aug 2026
Measure Theory and Filtering: Introduction and Applications: 15 (Cambridge Series in Statistical and Probabilistic Mathematics, Series Number 15)
80% match

Measure Theory and Filtering: Introduction and Applications: 15 (Cambridge Series in Statistical and Probabilistic Mathematics, Series Number 15)

Cambridge University Press
£80.75 13 Aug 2026
Mobile Robot Localization and Map Building: A Multisensor Fusion Approach
80% match

Mobile Robot Localization and Map Building: A Multisensor Fusion Approach

Springer
£115.70 08 Aug 2026
Mobile Robot Localization and Map Building: A Multisensor Fusion Approach
80% match

Mobile Robot Localization and Map Building: A Multisensor Fusion Approach

Springer

£108.01 05 Aug 2026
Density Ratio Estimation in Machine Learning
80% match

Density Ratio Estimation in Machine Learning

Cambridge University Press
£104.00 01 Oct 2026
Robotic Mapping and Exploration: 55 (Springer Tracts in Advanced Robotics, 55)
80% match

Robotic Mapping and Exploration: 55 (Springer Tracts in Advanced Robotics, 55)

Springer
£76.42 06 Aug 2026
Inductive Biases in Machine Learning for Robotics and Control: 156 (Springer Tracts in Advanced Robotics, 156)
80% match

Inductive Biases in Machine Learning for Robotics and Control: 156 (Springer Tracts in Advanced Robotics, 156)

Springer

£92.22 30 Jul 2026