We can't find the internet
Attempting to reconnect
Something went wrong
Hang in there while we get back on track
£139.99
It has never been this cheap. We have no record of a lower price.
£140 today · cheaper than every other day in the last 1 months
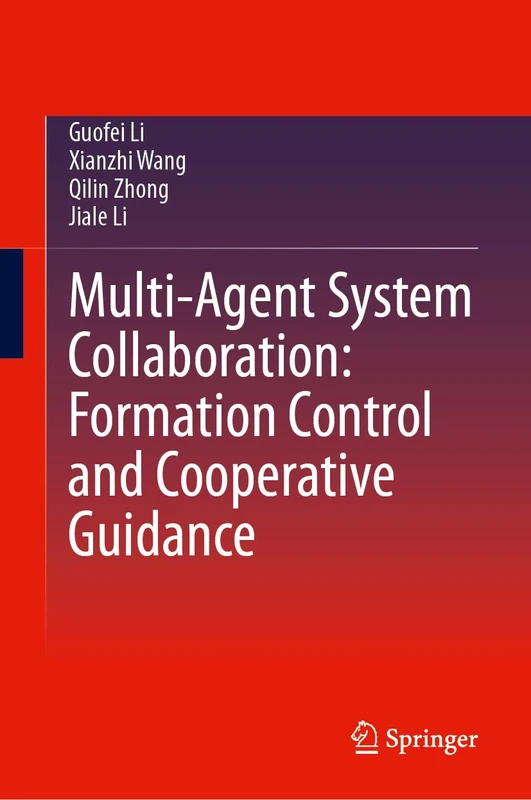
Springer Multi-Agent System Collaboration: Formation Control & Cooperative Guidance
We'll watch every seller, every day. One email when your price arrives.
Price History & Forecast
Grey patches = out of stock. Cheaper = lower on the chart. Hover for exact prices.
Last 9 days · 9 data points (no recent data)
NEW HERE?
Amazon shows you one price. We show you all of them.
Tosheroon watches Amazon prices so you don't have to. Every product on Amazon has a price history — we make it visible. Set the price you'd actually pay, and we'll email you the second it gets there. No app, no account, one email.
WHAT'S ON THIS PAGE
when this has been cheap or pricey
where the price is heading next
all-time high & low, recent range
name your number, we'll email you
Price Distribution
Price distribution over 9 days • 1 price levels
Price Analysis
Most common price: £140 (9 days, 100.0%)
Price range: £140 - £140
Price levels: 1 different prices over 9 days
Description
Key Features
Springer publication offers comprehensive theoretical analysis backing all presented formation control and cooperative guidance methods.
Multi-agent system collaboration framework addresses practical constraints including cyber attacks, physical limitations, and obstacle avoidance.
Methods presented in this book adapt to diverse real-world scenarios, making research outcomes applicable across multiple engineering contexts.
Formation control approaches integrate cooperation principles essential for autonomous systems and distributed agent coordination.
Product Specifications
- Brand
- Springer
- Format
- hardcover
- ASIN
- 9819599962
- Domain
- Amazon UK
- Release Date
- 28 October 2026
- Listed Since
- 17 March 2026
Barcode
No barcode data available
Similar Products You Might Like
Cooperative Control of Multi-Agent Systems: Optimal and Adaptive Design Approaches (Communications and Control Engineering)
Springer
Cooperative Coordination and Formation Control for Multi-agent Systems (Springer Theses)
Springer
Fault-Tolerant Cooperative Control of Unmanned Aerial Vehicles
Springer
Cooperative Control of Multi-Agent Systems: Theory and Applications
Wiley
Multiagent Coordination Enabling Autonomous Logistics
Springer
Cooperative Coordination and Formation Control for Multi-agent Systems (Springer Theses)
Springer
Time-Varying Formation Tracking Control for Nonlinear Swarm Systems
Springer
Collaborative Perception, Localization and Mapping for Autonomous Systems: 2 (Springer Tracts in Autonomous Systems, 2)
Springer
Collaborative Perception, Localization and Mapping for Autonomous Systems: 2 (Springer Tracts in Autonomous Systems, 2)
Springer
Coordination of Large-Scale Multiagent Systems
Springer
Coordination of Large-Scale Multiagent Systems
Springer
Real-Time Search for Learning Autonomous Agents: 406 (The Springer International Series in Engineering and Computer Science, 406)
Springer
Cooperative Control of Multi-agent Systems: A Hybrid System Approach
Springer
Distributed Average Tracking in Multi-agent Systems
Springer
Distributed Cooperative Control and Optimization for Multi-Agent Systems
Springer
Distributed Localization and Formation Control of Multi-Agent Systems with Local Sensing Information
Springer
Swarm Stability and Optimization
Springer
Stabilization, Tracking and Formation Control of Autonomous Marine Vessels
Springer
Distributed Cooperative Control and Optimization for Multi-Agent Systems
Springer
Cooperative Control of Distributed Multi-Agent Systems
Wiley
Motion Coordination for VTOL Unmanned Aerial Vehicles: Attitude Synchronisation and Formation Control (Advances in Industrial Control)
Springer
Cooperative Control: Models, Applications and Algorithms: 1 (Cooperative Systems, 1)
Springer
Innovations in Multi-Agent Systems and Application – 1: 310 (Studies in Computational Intelligence, 310)
Springer
Distributed Heterogeneous Multi Sensor Task Allocation Systems: 7 (Automation, Collaboration, & E-Services, 7)
Springer