We can't find the internet
Attempting to reconnect
Something went wrong
Hang in there while we get back on track
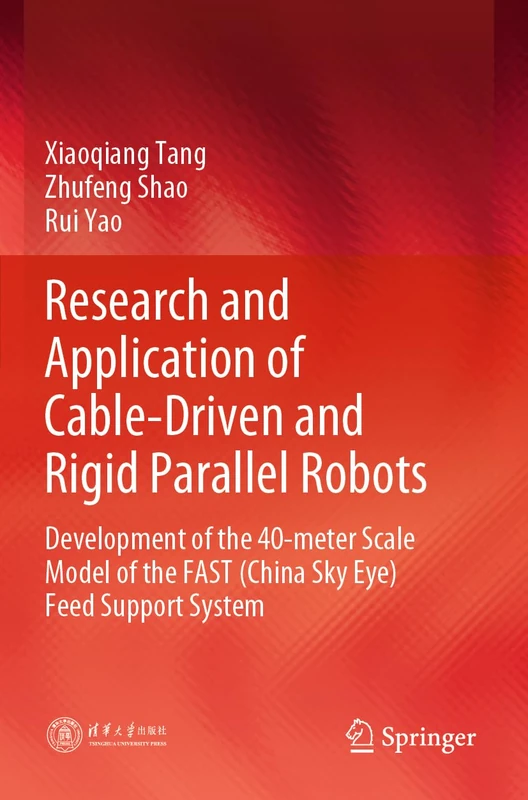
£100.11
It has never been this cheap. We have no record of a lower price.
£100 today · cheaper than every other day in the last 3 months
Springer Research and Application of Cable-Driven and Rigid Parallel Robots: Development of the 40-meter Scale Model of the FAST (China Sky Eye) Feed Support System
We'll watch every seller, every day. One email when your price arrives.
Price History & Forecast
Grey patches = out of stock. Cheaper = lower on the chart. Hover for exact prices.
Last 23 days · 23 data points (no recent data)
NEW HERE?
Amazon shows you one price. We show you all of them.
Tosheroon watches Amazon prices so you don't have to. Every product on Amazon has a price history — we make it visible. Set the price you'd actually pay, and we'll email you the second it gets there. No app, no account, one email.
WHAT'S ON THIS PAGE
when this has been cheap or pricey
where the price is heading next
all-time high & low, recent range
name your number, we'll email you
Price Distribution
Price distribution over 23 days • 2 price levels
Price Analysis
Most common price: £100 (17 days, 73.9%)
Price range: £100 - £106
Price levels: 2 different prices over 23 days
Description
Product Specifications
- Brand
- Springer
- Format
- paperback
- ASIN
- 9819974542
- Domain
- Amazon UK
- Release Date
- 01 February 2025
- Listed Since
- 25 January 2025
Barcode
No barcode data available
Similar Products You Might Like
Cable-Driven Parallel Robots: Proceedings of the 4th International Conference on Cable-Driven Parallel Robots: 74 (Mechanisms and Machine Science, 74)
Springer
Parallel Robotic Machine Tools
Springer
Parallel Robots: Mechanics and Control
CRC Press
Parallel Robots: 128 (Solid Mechanics and Its Applications, 128)
Springer
Analysis and Synthesis of Compliant Parallel Mechanisms―Screw Theory Approach: 139 (Springer Tracts in Advanced Robotics, 139)
Springer
Advances in Robot Kinematics
Springer
Structural Synthesis of Parallel Robots: Part 1: Methodology: 149 (Solid Mechanics and Its Applications, 149)
Springer
Distributed Autonomous Robotic Systems
Springer
Theory and Applications of Multi-Tethers in Space (Springer Tracts in Mechanical Engineering)
Springer
Dynamics of Parallel Robots (Parallel Robots: Theory and Applications)
Springer
Passivity-Based Control and Estimation in Networked Robotics (Communications and Control Engineering)
Springer
Multi-Arm Cooperating Robots: Dynamics and Control: 30 (Intelligent Systems, Control and Automation: Science and Engineering, 30)
Springer
Kinematic Analysis of Robot Manipulators
Cambridge University Press
The “Hand-eye-brain” System of Intelligent Robot: From Interdisciplinary Perspective of Information Science and Neuroscience (Research on Intelligent Manufacturing)
Springer
Robotic Vehicles: Systems and Technology
Springer
Robot Force Control: 540 (The Springer International Series in Engineering and Computer Science, 540)
Springer
Robot Force Control: 540 (The Springer International Series in Engineering and Computer Science, 540)
Springer

Advances in Robotics and Optimization Approach in Engineering
CWP PUBLISHING
Parallel Robots With Unconventional Joints: Kinematics and Motion Planning (Parallel Robots: Theory and Applications)
Springer

Radio Telescope Reflectors: Historical Development of Design and Construction: 447 (Astrophysics and Space Science Library, 447)
Springer
Autonomous Tracked Robots in Planar Off-Road Conditions: Modelling, Localization, and Motion Control: 6 (Studies in Systems, Decision and Control, 6)
Springer
Robot Mechanisms: 60 (Intelligent Systems, Control and Automation: Science and Engineering, 60)
Springer
Fundamentals of Mechanics of Robotic Manipulation: Science and Engineering): 27 (Intelligent Systems, Control and Automation: Science and Engineering)
Springer
Advanced Mechanics in Robotic Systems
Springer