We can't find the internet
Attempting to reconnect
Something went wrong
Hang in there while we get back on track
£71.00
It has never been this cheap. We have no record of a lower price.
£71 today · cheaper than every other day in the last 3 months
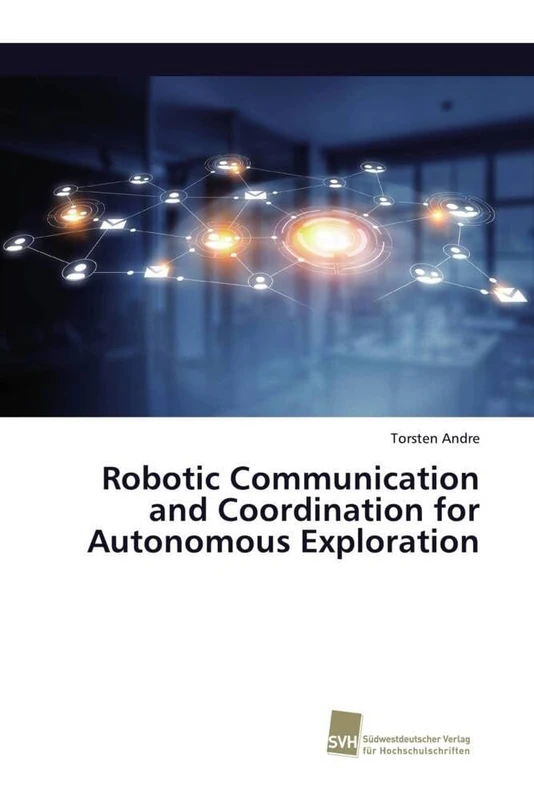
Südwestdeutscher Verlag für Hochschulschriften Robotic Communication and Coordination for Autonomous Exploration
Price data last checked 33 day(s) ago - refreshing...
We'll watch every seller, every day. One email when your price arrives.
Price History & Forecast
Grey patches = out of stock. Cheaper = lower on the chart. Hover for exact prices.
Last 58 days · 58 data points (no recent data)
Price data last checked 33 day(s) ago - refreshing...
NEW HERE?
Amazon shows you one price. We show you all of them.
Tosheroon watches Amazon prices so you don't have to. Every product on Amazon has a price history — we make it visible. Set the price you'd actually pay, and we'll email you the second it gets there. No app, no account, one email.
WHAT'S ON THIS PAGE
when this has been cheap or pricey
where the price is heading next
all-time high & low, recent range
name your number, we'll email you
Price Distribution
Price distribution over 58 days • 1 price levels
Price Analysis
Most common price: £71 (58 days, 100.0%)
Price range: £71 - £71
Price levels: 1 different prices over 58 days
Description
Product Specifications
- Format
- paperback
- ASIN
- 3838153901
- Domain
- Amazon UK
- Release Date
- 02 June 2017
- Listed Since
- 28 June 2017
Barcode
No barcode data available
Similar Products You Might Like
Distributed Autonomous Robotic Systems
Springer
Gebietserkundung mit autonomen Robotern: Implementierung eines dynamischen und kooperativen Gebietserkundungsverfahrens für Robertinos
VDM Verlag
A Distributed Multiagent Architecture: for Remote Multirobot Interaction
LAP Lambert Academic Publishing
Collaborative Perception, Localization and Mapping for Autonomous Systems: 2 (Springer Tracts in Autonomous Systems, 2)
Springer
Collaborative Perception, Localization and Mapping for Autonomous Systems: 2 (Springer Tracts in Autonomous Systems, 2)
Springer
Robotic Mapping and Exploration: 55 (Springer Tracts in Advanced Robotics, 55)
Springer
Distributed Robot Flocking Control: Communication and Cooperation of Multiple Robots
LAP Lambert Academic Publishing
Perceptual Inference for Autonomous Navigation: Vegetation Detection and Terrain Classification
Südwestdeutscher Verlag für Hochschulschriften
Robot Colonies
Springer
Visual localisation for AIBO walking robots: A hybrid approach to fast and accurate localisation for legged robots
VDM Verlag
Multiagent Coordination Enabling Autonomous Logistics
Springer
Robot Colonies
Springer
Robot-Assited Search and Rescue: Self-Organised exploration team
LAP Lambert Academic Publishing
Scheduling and Motion Coordination of Autonomous Vehicles: Task Allocation and Motion Coordination of Multiple Autonomous Vehicles in Outdoor Material Handling Systems
LAP Lambert Academic Publishing
Multi-Robot Systems: Coordinated Fencing Control and Applications (Cognitive Intelligence and Robotics)
Springer
Navigation Control and Signal Processing Methods for Multiple Autonomous Unmanned Systems

Symbiotic Multi-Robot Organisms: Reliability, Adaptability, Evolution: 7 (Cognitive Systems Monographs, 7)
Springer
Coordination of Large-Scale Multiagent Systems
Springer
Multi Robot Cooperative System for Object Detection
LAP Lambert Academic Publishing
A Modular Framework for Multi-robot Localization Scenarios: Developing and Distributing Localization Algorithms Utilizing Kalman Filter Estimators, for Mobile Multi-robot Systems
LAP Lambert Academic Publishing
Autonomous Surface Exploration for Mobile Robots: Using Information Metrics to Plan Paths for Robotic Exploration
LAP Lambert Academic Publishing
Space-Time Continuous Models of Swarm Robotic Systems: Supporting Global-to-Local Programming: 9 (Cognitive Systems Monographs, 9)
Springer
Multi-Robot Systems: From Swarms to Intelligent Automata, Volume II: 2
Springer
Advanced robotic applications: Performance improvement techniques for industrial robots acting at the macro- and micro-scale
VDM Verlag