We can't find the internet
Attempting to reconnect
Something went wrong
Hang in there while we get back on track
£55.00
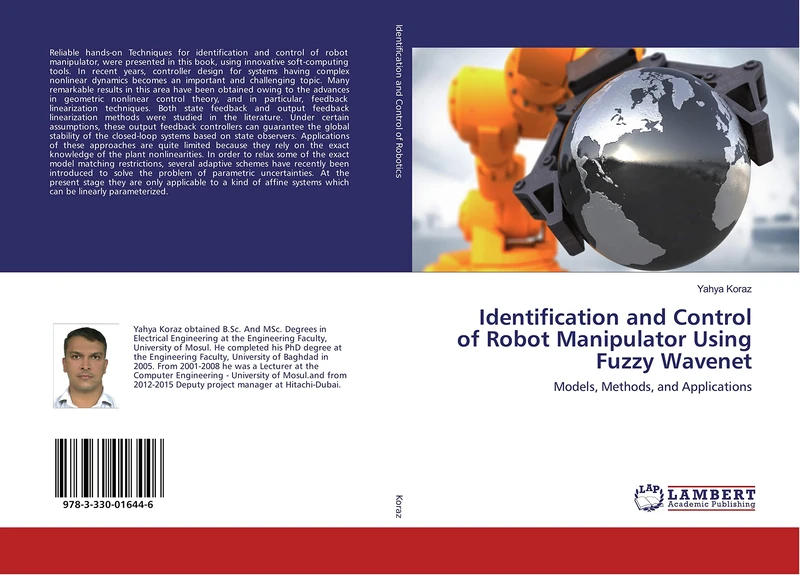
LAP Lambert Academic Publishing Identification and Control of Robot Manipulator Using Fuzzy Wavenet: Models, Methods, and Applications
Price data last checked 22 day(s) ago - will refresh soon
We'll watch every seller, every day. One email when your price arrives.
It has never been this cheap. We have no record of a lower price.
£55 today · cheaper than every other day in the last 3 months
NEW HERE?
Amazon shows you one price. We show you all of them.
Tosheroon watches Amazon prices so you don't have to. Every product on Amazon has a price history — we make it visible. Set the price you'd actually pay, and we'll email you the second it gets there. No app, no account, one email.
WHAT'S ON THIS PAGE
when this has been cheap or pricey
where the price is heading next
all-time high & low, recent range
name your number, we'll email you
Price History & Forecast
Grey patches = out of stock. Cheaper = lower on the chart. Hover for exact prices.
Last 69 days · 69 data points (no recent data)
Price Distribution
Price distribution over 69 days • 1 price levels
Price Analysis
Most common price: £55 (69 days, 100.0%)
Price range: £55 - £55
Price levels: 1 different prices over 69 days
Description
Product Specifications
- Format
- paperback
- ASIN
- 3330016442
- Domain
- Amazon UK
- Release Date
- 05 December 2016
- Listed Since
- 12 April 2016
Barcode
No barcode data available
Similar Products You Might Like
Nonlinear Control of Vehicles and Robots (Advances in Industrial Control)
Springer
Nonlinear and Adaptive Control with Applications (Communications and Control Engineering)
Springer
Controlsystems using fuzzylogic modeling in state space format
LAP Lambert Academic Publishing
Task-Space Sensory Feedback Control of Robot Manipulators: 73 (Intelligent Systems, Control and Automation: Science and Engineering, 73)
Springer
Formation Maneuvers of Autonomous Mobile Robots
LAP Lambert Academic Publishing

CONTROL TECHNIQUES FOR NONLINEAR SYSTEM: Modeling, analysis, tuning and control of nonlinear system using intelligent controllers
LAP Lambert Academic Publishing
Modelling and Identification in Robotics (Advances in Industrial Control)
Springer
Adaptive and Fault-Tolerant Control of Underactuated Nonlinear Systems (Automation and Control Engineering)
CRC Press
Output Feedback Control for Slosh-free Motion: A Sliding Mode Approach: Robust Output Feedback Control
LAP Lambert Academic Publishing
Wheeled Mobile Robot Control: Theory, Simulation, and Experimentation: 380 (Studies in Systems, Decision and Control, 380)
Springer
Feedback Controller Design for Simultaneous Stabilization: Methods to Construct Simultaneously Stabilizing Controllers and Rational Polynomials with Interpolation Constraints
LAP Lambert Academic Publishing

Mekhatronno-modul'nye roboty s adaptivnoy kinematicheskoy strukturoy: Modeli, algoritmy i programmnoe obespechenie sistem upravleniya
LAP Lambert Academic Publishing
Nonlinear and Adaptive Control of Complex Systems: 491 (Mathematics and Its Applications, 491)
Springer
Fundamentals in Modeling and Control of Mobile Manipulators (Automation and Control Engineering)
CRC Press
New Trends in Robot Control: 270 (Studies in Systems, Decision and Control, 270)
Springer
Advances and Applications in Nonlinear Control Systems: 635 (Studies in Computational Intelligence, 635)
Springer

Advances and Applications in Nonlinear Control Systems: 635 (Studies in Computational Intelligence, 635)
Springer
Adaptive Critic Control with Robust Stabilization for Uncertain Nonlinear Systems: 167 (Studies in Systems, Decision and Control, 167)
Springer
Multi-Arm Cooperating Robots: Dynamics and Control: 30 (Intelligent Systems, Control and Automation: Science and Engineering, 30)
Springer
Linear Algebra Based Controllers: Design and Applications
Springer
Linear Algebra Based Controllers: Design and Applications
Springer
Nonlinear Control of Fixed-Wing UAVs with Time-Varying and Unstructured Uncertainties: 1 (Springer Tracts in Autonomous Systems, 1)
Springer
Design of Linear Multivariable Feedback Control Systems: The Wiener–Hopf Approach using Transforms and Spectral Factorization
Springer

Explicit Nonlinear Model Predictive Control: Theory and Applications: 429 (Lecture Notes in Control and Information Sciences, 429)
Springer